









| 查看: 359 | 回复: 1 | ||
| 本帖产生 1 个 ,点击这里进行查看 | ||
baroshi木虫 (正式写手)
|
[求助]
帮忙查一下此论文有没有被检索
|
|

|
An asynchronous sensor bias estimation algorithm utilizing targets’ positions only [ 发自手机版 https://muchong.com/3g ] |
 回复此楼
» 猜你喜欢
 售SCI-T0P文章,我:8O.5.5.1.O.54,科目齐全,可+急
已经有5人回复
-
售SCI一区T0P文章,我:8O.55.1.O.5.4,科目齐全,可+急
已经有4人回复
-
上海工程技术大学 激光智能制造课题组 2027级博士研究生招生
已经有6人回复
-
课题组招2027级博士 上海工程技术大学 激光智能制造方向
已经有6人回复
-
现代”学阀”该如何界定
已经有14人回复
-
求合成方法
已经有8人回复
-
师弟论文见刊大半年才想起来申请专利,还能抢救一下吗?
已经有4人回复
-
有机合成以后会不会被AI改变?做科研的虫友怎么看
已经有8人回复
-
我的奶奶
已经有3人回复

wgc1912
荣誉版主 (文坛精英)
十二哥哥

- 应助: 112 (高中生)
- 贵宾: 19.229
- 金币: 100644
- 散金: 34802
- 红花: 358
- 沙发: 204
- 帖子: 15835
- 在线: 3811.9小时
- 虫号: 1512499
- 注册: 2011-11-27
- 性别: GG
- 专业: 能源化工
- 管辖: 文献求助
【答案】应助回帖
★ ★ ★ ★ ★
感谢参与,应助指数 +1
baroshi: 金币+5, ★★★★★最佳答案 2015-07-31 12:40:09
心静_依然: LS-EPI+1, 感谢应助 2015-07-31 12:56:58
感谢参与,应助指数 +1
baroshi: 金币+5, ★★★★★最佳答案 2015-07-31 12:40:09
心静_依然: LS-EPI+1, 感谢应助 2015-07-31 12:56:58
SCI未检索 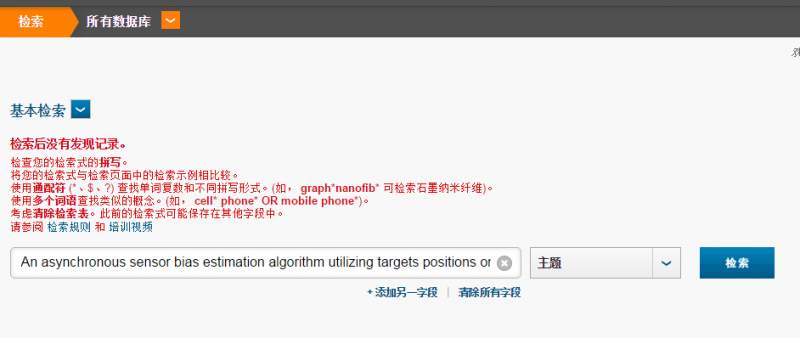 EI已检索 Accession number:20152600974870 Accession number:20152600974870 Title: An asynchronous sensor bias estimation algorithm utilizing targets' positions only Authors: Yong, Xiaoju1 Email author yongxiaoju1987@126.com; Fang, Yangwang1 Email author ywfang2008@sohu.com; Wu, Youli1 Email author ylwu@126.com; Yang, Pengfei1 Email author pfyang@126.com Author affiliation: 1 School of Aeronautics and Astronautics Engineering, Air Force Engineering University, Xi'an, Shanxi, China Corresponding author: Yong, Xiaoju Source title: Information Fusion Abbreviated source title: Inf. Fusion Volume: 27 Issue date: June 23, 2016 Publication year: 2015 Pages: 54-63 Language: English ISSN: 15662535 Document type: Journal article (JA) Publisher: Elsevier Abstract: Bias estimation is a critical problem in multi-sensor tracking systems, and most existing research has focused on the bias estimation of synchronous sensors; however, in practical applications, sensor measurements are usually asynchronous. The primary contribution of this paper is that a novel algorithm using B-spline interpolation time registration to achieve asynchronous sensor bias estimation is proposed. First, measurements are transformed into synchronous data using the B-spline interpolation time registration method. The time registration results are expressed as weighted results of the measurements. Second, a pseudo measurement equation is created based on the synchronous data. Compared with the pseudo measurements of other algorithms that use weighting coefficients, which are calculated by the target's state, including the target's velocity and time of arrival (TOA), a pseudo measurement that only depends on the target's position can be derived. Thus, the problem of asynchronous sensor bias estimation, particularly with manoeuvring targets, can be solved effectively by the proposed algorithm. Finally, the effectiveness of the proposed algorithm is verified by simulations with the target performing s-shaped manoeuvres. Monte Carlo simulation results indicate that the Cramer-Rao lower bound (CRLB) is achievable; thus, the proposed algorithm is statistically efficient. © 2015 Elsevier B.V. All rights reserved. Number of references: 19 Main heading: Algorithms Controlled terms: Cramer-Rao bounds - Data fusion - Intelligent systems - Interpolation - Monte Carlo methods Uncontrolled terms: Asynchronous sensor - B-spline interpolations - Bias estimation - Cramer-rao lower bound - Manoeuvring target - Multisensor tracking system - Spatial registrations - Weighting coefficient Classification code: 723 Computer Software, Data Handling and Applications - 921 Mathematics - 921.6 Numerical Methods - 922.2 Mathematical Statistics DOI: 10.1016/j.inffus.2015.05.003 |
2楼2015-07-31 07:55:36